The English version of this page is being translated and reviewed; the Thai original is shown for now.
Camera calibration with sample images
ประมาณ camera matrix และ distortion
L11 · แนวทางทดลอง
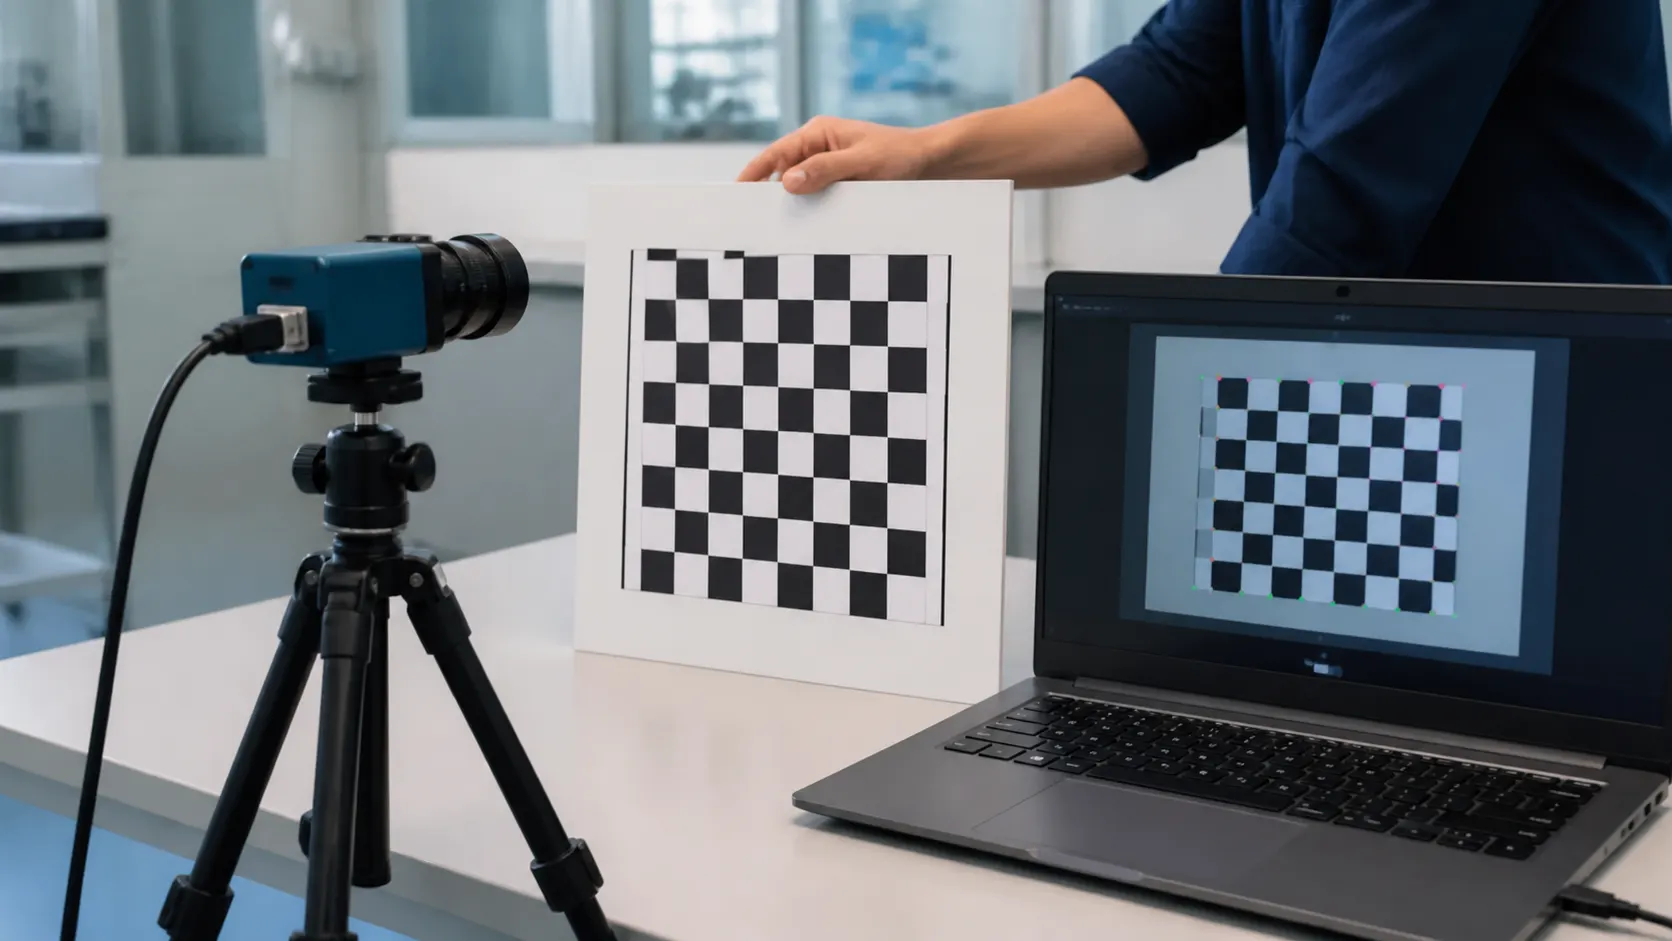
ประมาณ camera matrix และ distortion
อ่านหลักการ: Computer Vision และ Edge AI
สิ่งที่ต้องเตรียม
OpenCV CPU และภาพ chessboard จาก tutorial
เลือกขั้นตอนติดตั้งที่ตรง Windows/Linux และตรึงรุ่นตามคู่มือต้นทาง รายการนี้ยังเป็นโจทย์ทดลอง ไม่ใช่บันทึกผลที่รันผ่านแล้ว
ลำดับทดลอง
- อ่านจำนวน inner corners และหน่วยของขนาดช่องให้ถูก
- ตรวจมุม chessboard ในหลายมุมมอง แล้วใช้ชุดภาพ calibration
- คำนวณ camera matrix/distortion และ undistort ภาพ
- เปรียบเทียบ reprojection error รายภาพและตรวจภาพที่ error สูง
ผลลัพธ์ที่ควรเก็บ
camera matrix, coefficients, ภาพก่อนหลัง และ error
ตรวจความเข้าใจและผลที่ได้
บันทึก image resolution และขนาดช่อง; อธิบาย outlier ได้
ขอบเขตการตีความ
calibration ใช้กับชุดกล้อง/เลนส์/ความละเอียดที่สอดคล้องกัน
Used in courses
How to cite this page
Drone Institute, Rangsit University. (2026). Camera calibration with sample images. In UAS Technology Knowledge Hub (B.Tech.). https://rsu-drt.pk-research.work/en/kb/labs/l11/